
What to Compare When Selecting High Torque Precision Gearboxes for Servo Drives
Selecting a gearbox for a servo axis often starts with torque, but that is rarely where the real decision ends. Technical evaluators searching for high torque precision gearboxes are usually trying to answer a more practical question: which gearbox will preserve motion accuracy under load, survive repeated dynamic cycles, and fit the machine architecture without creating avoidable reliability problems. In other words, the gearbox is not being judged as an isolated part. It is being judged as a control, mechanical, thermal, and lifecycle component inside a larger system.
That matters because servo-driven equipment is increasingly expected to do two things at the same time: deliver higher output torque and maintain tighter positioning performance. In packaging, robotics, machine tools, converting equipment, material handling, and heavy automation, buyers are no longer comparing only nameplate values. They are comparing how the gearbox behaves when acceleration is aggressive, loads reverse direction frequently, duty cycles are dense, and downtime is expensive.
The most common mistake in early selection is assuming that a gearbox with sufficient rated torque is automatically suitable. In practice, the better comparison starts with the application profile: continuous torque, peak torque, shock load exposure, indexing frequency, positioning tolerance, inertia ratio, mounting direction, ambient temperature, and available lubrication strategy. Once those conditions are clear, the gearbox comparison becomes much more disciplined.
Start with the duty profile, not the catalog headline
High torque means different things in different servo applications. A rotary table with long dwell periods and occasional indexing has a different risk profile from a continuous web-handling axis, an AGV drive, or a robot joint that sees frequent reversals. A gearbox that performs well in one case may run hot, lose accuracy, or wear prematurely in another.
Before comparing models, evaluators should define at least these operating conditions:
- Continuous output torque and peak torque duration
- Input speed range and maximum motor speed
- Acceleration and deceleration frequency
- Load inertia and reflected inertia to the motor
- Required positioning accuracy and repeatability
- Duty cycle over a shift or full operating day
- Shock loading, emergency stop behavior, and overload events
- Ambient temperature, contamination, washdown, or corrosive exposure
This step sounds basic, but it is where many comparison errors begin. Suppliers often present rated values under standardized conditions that do not represent the actual motion profile. If your servo axis spends most of its time near peak acceleration, thermal limits and fatigue behavior can become more important than nominal torque capacity.
Backlash is important, but it is not the whole precision story
Backlash usually gets the most attention because it is easy to quote and easy to compare. It also matters, especially in indexing, bidirectional positioning, synchronized motion, and robotic applications. But experienced buyers know that low backlash on paper does not automatically guarantee better machine performance over time.
Three related questions matter more than the backlash number alone:
- What is the initial backlash under inspection conditions?
- How stable is that backlash after running-in and after extended load cycles?
- How does the gearbox behave under load reversals, not just at no-load measurement?
A gearbox may show very low initial backlash but lose its precision advantage faster if the bearing support, gear geometry, preload design, or lubrication management is less robust. For servo systems that depend on repeatable contouring or tight registration, torsional rigidity often deserves equal weight. Lower backlash with poor stiffness can still produce deflection, settling delay, and control instability under high torque demand.
In practical evaluation, it is better to compare backlash and torsional rigidity together. Backlash influences deadband and reversal accuracy. Torsional rigidity influences elastic deformation under torque. The machine sees both.
Torsional rigidity often separates acceptable performance from stable performance
For high torque servo drives, torsional rigidity is one of the most underappreciated decision factors. When rigidity is insufficient, the servo loop may still function, but the axis can exhibit lag, overshoot, settling problems, vibration sensitivity, or reduced contour accuracy. These issues are especially visible in applications with frequent start-stop motion, heavy tooling, or tightly coordinated multi-axis movement.
Evaluators should ask for stiffness data in a form that can be related to the actual application, not just a general claim of “high rigidity.” If the supplier provides torsional stiffness values, confirm whether they are measured at the gearbox output and under what torque range. Also check whether the value reflects the whole gearbox assembly, including bearing support, or mainly the gear mesh itself.
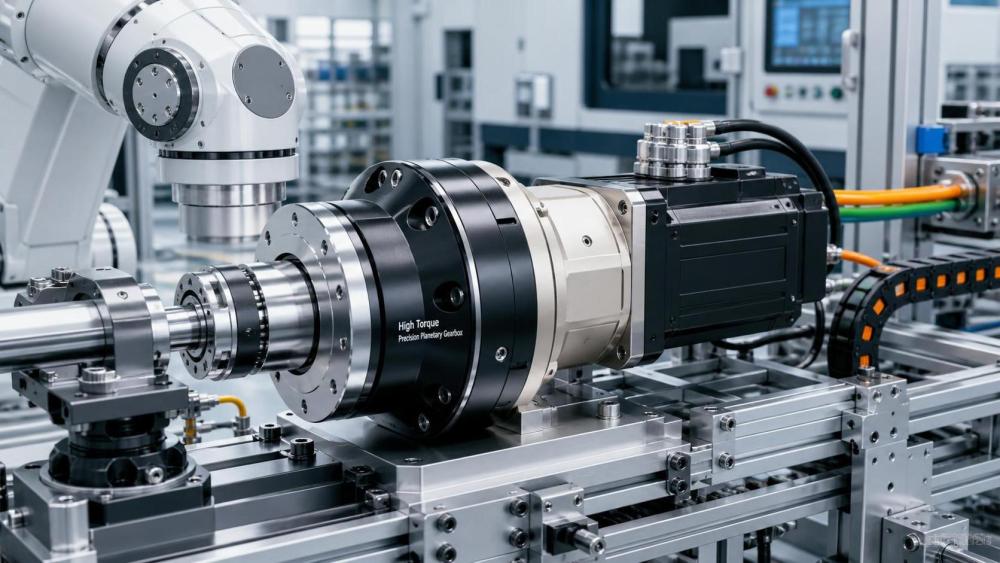
In servo selection meetings, this is often the turning point: one gearbox may meet the torque requirement, while another provides the dynamic stability needed to keep control tuning practical. The cheaper unit can become more expensive if the controls team spends excessive time compensating for mechanical compliance that should have been designed out earlier.
Overload capacity should be compared with realism
Many applications do not fail under continuous load. They fail during peaks: sudden indexing, jam-clearing events, impact from product variation, or emergency stops. That is why overload capacity matters, but it must be interpreted carefully.
A quoted peak torque figure is only useful if you also understand duration and frequency. A gearbox that can tolerate a very high overload for milliseconds is not equivalent to one that can absorb repeated peak events throughout a shift. Technical buyers should compare:
- Permissible peak torque and allowable duration
- Maximum emergency stop torque response
- Shock load tolerance or service factor guidance
- Repetition limits for overload events
- Any warranty exclusions linked to transient loading
In real procurement reviews, this is where language can become vague. Terms such as “maximum torque” or “instant torque” are not always directly comparable across suppliers. If the application has known impact loading or irregular process disturbances, request clarification in writing. That reduces the risk of buying against a generous-looking number that is based on a test condition far removed from production reality.
Efficiency and thermal behavior are operational issues, not just engineering details
Transmission efficiency affects more than energy consumption. In high torque precision gearboxes, losses convert into heat, and heat changes lubrication condition, internal clearances, seal life, and long-term positioning consistency. In compact servo systems, thermal behavior can become the hidden limiter long before the mechanical torque limit is reached.
This is especially relevant when the gearbox is mounted in enclosed machine spaces, near heat-producing motors, or in applications with sustained cycling. Two gearboxes with similar torque ratings may perform very differently once temperature rises. One may maintain stable operation; the other may drift in accuracy or require more conservative duty settings.
Evaluators should compare:
- Nominal efficiency at relevant speed and load points
- Heat generation under continuous duty
- Recommended thermal derating conditions
- Lubrication type and relubrication expectations, if any
- Housing design and heat dissipation characteristics
If thermal data is not readily available, that is itself useful information. It may indicate that the supplier expects the buyer to validate performance independently. For critical axes, that is not necessarily disqualifying, but it means more application engineering work will be needed before approval.
Bearing support and radial or axial load capacity can change the shortlist quickly
Some gearbox comparisons stay too focused on the reducer internals and overlook external loading at the output interface. In many servo-driven machines, the gearbox output does more than transmit torque. It may also support pulleys, pinions, turntables, cantilevered tooling, or belt tension. That introduces radial and axial forces that can materially change bearing life and motion accuracy.
If output-side loads are meaningful, compare bearing arrangement and allowable overhung load carefully. A gearbox selected only by torque ratio and backlash can become unreliable if its output bearings are undersized for the real mechanical arrangement.
This is a frequent issue in retrofits and machine upgrades. Engineers may increase servo torque to improve throughput, then retain a gearbox footprint that was originally sized for lower dynamic loading. The result is not always immediate failure. More often, it appears as rising vibration, seal wear, increased backlash growth, or shortened maintenance intervals.
Mounting accuracy and interface quality matter more than many teams expect
Precision gearboxes are often evaluated by internal design quality, but installation accuracy has a direct effect on how much of that precision reaches the machine. Motor adapter concentricity, flange flatness, shaft alignment, coupling fit, and housing rigidity all influence actual system behavior.
For that reason, technical evaluators should review the gearbox as part of an interface stack:
- Motor connection standard and adapter precision
- Output flange or shaft tolerances
- Mounting stiffness of the machine frame
- Alignment requirements during assembly
- Availability of integrated pinion, hollow shaft, or custom interface options
Where application risk is high, dimensional repeatability from unit to unit also matters. A gearbox that performs well in prototype assembly but varies in interface precision during production supply can create hidden commissioning costs. This is particularly relevant for OEMs scaling a machine platform across multiple installations.
Service life claims should be tied to duty assumptions
Long life is commonly promised and loosely understood. In practice, gearbox life depends on load spectrum, input speed, lubrication condition, bearing loading, operating temperature, contamination, and motion profile. A long nominal life under moderate duty may not translate to an aggressive servo axis with frequent torque reversals.
Instead of accepting a generic lifespan statement, evaluators should ask how life is estimated. Is it primarily gear tooth fatigue, bearing life, lubrication life, or seal life that governs? Which assumptions are built into the calculation? Are those assumptions aligned with the intended use?
For buyer-side comparison, a few questions help expose differences quickly:
For high-availability equipment, the procurement decision should include not only expected life but failure consequence. A gearbox on a noncritical conveyor is one thing. A gearbox on a precision indexing station, robotic transfer axis, or automated machining cell is another.
Do not separate gearbox selection from servo tuning reality
One of the more misleading assumptions in equipment buying is that controls can compensate for almost any mechanical weakness. Servo tuning can improve performance, but it cannot eliminate poor rigidity, excessive backlash growth, thermal instability, or bearing deflection. If the gearbox is marginal, the controls team may be forced into conservative tuning that reduces the performance the machine was supposed to achieve.
This is why the best evaluations involve both mechanical and motion-control perspectives. The gearbox ratio, stiffness, efficiency, and inertia contribution all affect motor sizing, tuning window, and system responsiveness. A technically acceptable gearbox that complicates tuning may still be the wrong commercial choice if commissioning time, repeatability risk, and after-sales support burden are considered honestly.
Supplier capability is part of the technical comparison
For industrial buyers, especially in global sourcing environments, the gearbox itself is only part of the decision. Documentation quality, inspection capability, production consistency, and technical communication often determine whether the selected unit will perform reliably in series use.
When comparing suppliers of high torque precision gearboxes, it is reasonable to examine:
- Test methods for backlash, noise, temperature rise, and efficiency
- Traceability of critical materials and heat treatment
- Dimensional inspection process for mounting interfaces
- Consistency between prototype samples and production batches
- Lead time stability and spare parts availability
- Ability to support application-specific review, not just catalog supply
In many B2B projects, supply risk becomes visible only after technical selection. A gearbox may look competitive until custom ratios, special flanges, or validation documents are required. For OEMs and project-based buyers, that can reshape the final choice more than a small difference in purchase price.
Common selection shortcuts that deserve skepticism
Several market habits continue to distort gearbox comparison.
- Choosing by rated torque alone. This ignores duty cycle, shock events, and thermal limits.
- Using backlash as the sole proxy for precision. This overlooks stiffness and long-term stability.
- Assuming all planetary or precision gearbox designs are interchangeable. Internal geometry, bearing design, and manufacturing quality vary significantly.
- Ignoring the output-side load case. External radial and axial loads can dominate service life.
- Relying on catalog life without verifying application assumptions. This often leads to optimistic service expectations.
- Treating installation quality as secondary. Precision is easily lost through poor mounting practice.
None of these shortcuts are unusual, especially when procurement cycles are compressed. But each one increases the chance that the chosen gearbox will look correct in approval documents and become problematic in operation.
What a strong comparison process usually looks like
For technical evaluators, a disciplined comparison process is typically more valuable than an extra page of specifications. In practical terms, the better path is to narrow candidates by application fit, then compare a smaller set using real operating conditions. That means matching torque and ratio first, then screening for stiffness, backlash stability, thermal behavior, overload response, bearing support, interface quality, and supplier capability.
If the application is critical, bench validation or supplier-supported simulation is often justified. Even limited validation under representative duty can reveal issues that a specification sheet will not. Where data is incomplete, note it explicitly as a decision risk rather than treating missing information as neutral.
For most buyers, the right gearbox is not the one with the most aggressive single parameter. It is the one whose performance claims stay coherent when torque, control precision, thermal load, installation reality, and production reliability are considered together. That is the point where gearbox selection stops being a catalog exercise and becomes an engineering decision.
Related News
- How to Assess a Rigid Coupling Supplier for Bore Accuracy and Traceable QualityOct 08, 2026Tribology & Kinematics Expert
- Titanium Alloys Compared: Balancing Strength, Corrosion Resistance, and MachinabilityOct 08, 2026CNC Kinematics Architect
- Where Ductile Iron Dismantling Joints Reduce Alignment Risk in Water PipelinesOct 08, 2026Pipeline Metallurgy Scientist
- Selecting a Precision Bearing Sleeve: Fits, Runout, and Material ChoicesOct 08, 2026Tribology & Kinematics Expert
- Face Milling Cutters: How Insert Geometry Affects Finish on Steel and AluminumOct 08, 2026CNC Kinematics Architect
- Single-Acting Cylinders for Clamping: Stroke, Force, and Return Spring ConsiderationsOct 07, 2026Fluid Power Control Strategist