
Fast Response Pneumatic Valves: Matching Response Time to Automation Cycle Rates
A packaging line may run smoothly at a moderate rate and then begin missing stops, producing uneven clamp force, or losing repeatability after the cycle time is reduced. The immediate reaction is often to specify a faster solenoid valve. That can help, but only when the valve is the limiting element. In a real pneumatic circuit, the motion seen at the actuator is the combined result of electrical command delay, valve switching, air delivery, cylinder filling or exhausting, load movement, cushioning, and sensor confirmation.
The practical rule is simple: match the valve’s verified switching behavior and flow capacity to the time remaining inside the machine cycle, not merely to the controller output speed. Fast response pneumatic valves should be selected from a complete timing budget. A valve with a short published response time can still produce slow or inconsistent cylinder motion when tubing is restrictive, exhaust is throttled, supply pressure falls during simultaneous motion, or the valve is mounted too far from the actuator.
Start with the cycle-time budget
Before comparing valve catalogs, separate the motion into the events that actually consume time. A cylinder does not need to complete every part of its stroke at the same rate. In many mechanisms, it must reach a work position quickly, settle without rebound, apply force for a defined period, and retract before another axis enters the same zone. The permissible valve delay is therefore only one portion of the available interval.
A usable timing budget can be expressed as:
Available valve-related time = allowed motion window − controller/output delay − cylinder travel time − settling time − sensor confirmation margin.
This is not a universal formula for predicting exact motion. It is a disciplined way to avoid assigning the full cycle window to the valve. If the remaining margin is very small, a conventional valve may be unsuitable even if its nominal switching time appears close to the requirement. Conversely, an extremely fast valve is unnecessary when mechanical travel and stabilization dominate the cycle.
Build the budget around the most demanding repeatable sequence, rather than the average sequence. Consider start-up pressure, the number of actuators moving together, temperature, expected component aging, and whether the machine must recover from an interrupted cycle. A sequence that works only with a fully charged receiver and one axis operating is not a reliable basis for valve selection.
Response time is not one number
Catalog descriptions can use “response time,” “operate time,” “release time,” “on time,” or “off time” in different ways. These terms may refer to electrical energization through spool movement, pilot pressure build-up, or a measured outlet-pressure change under a specific test arrangement. They do not automatically represent the time from a PLC command to cylinder motion.
For directional control, separate the following events during evaluation:
- Output activation: the controller or remote I/O changes the electrical signal to the coil.
- Coil and armature response: magnetic force develops and the moving element begins to shift.
- Main flow-path switching: a poppet, spool, or pilot-operated stage reaches a position that connects supply or exhaust.
- Pressure propagation: air fills the line and actuator chamber, or exhausts from it.
- Mechanical response: breakaway friction is overcome and the load starts moving.
- End-of-motion confirmation: the actuator reaches a position and the feedback device changes state.
The first three are commonly associated with the valve. The latter three are strongly affected by the installation and mechanism. A fast valve can improve the first portion while leaving the end-to-end response almost unchanged if the downstream volume and restrictions are excessive.
Also distinguish between energize and de-energize behavior. Spring-return valves, pilot-operated valves, and valves with different supply and exhaust paths may have unequal switching times in the two directions. That difference matters in reject stations, safety-related return functions, clamping sequences, and high-speed reciprocating actuators. A specification that lists only one response figure leaves an important uncertainty.
Check the valve test condition before treating the figure as comparable
Response values are meaningful only with their stated test conditions. Ask whether the manufacturer identifies supply pressure, voltage tolerance, coil type, fluid condition, mounting orientation where relevant, and the pressure threshold used to define switching. A value measured at nominal voltage and a stable laboratory supply may not represent behavior at the end of a long cable run or during a period of high manifold demand.
For pilot-operated designs, minimum pilot pressure deserves particular attention. Below the required pressure differential, the main stage may shift slowly, incompletely, or not at all. Internal pilot supply, external pilot supply, and pilot exhaust arrangements can change both response and suitability. A circuit that must switch at low working pressure or use vacuum on one port may need a valve architecture different from a standard internally piloted spool valve.
When comparing alternatives, do not compare one maker’s electrical response figure directly with another maker’s pressure-rise or actuator-motion figure. Align the definitions first. Where cycle performance is critical, evaluate representative valves on the intended manifold, with the expected actuator, tubing route, fittings, load, and supply condition.
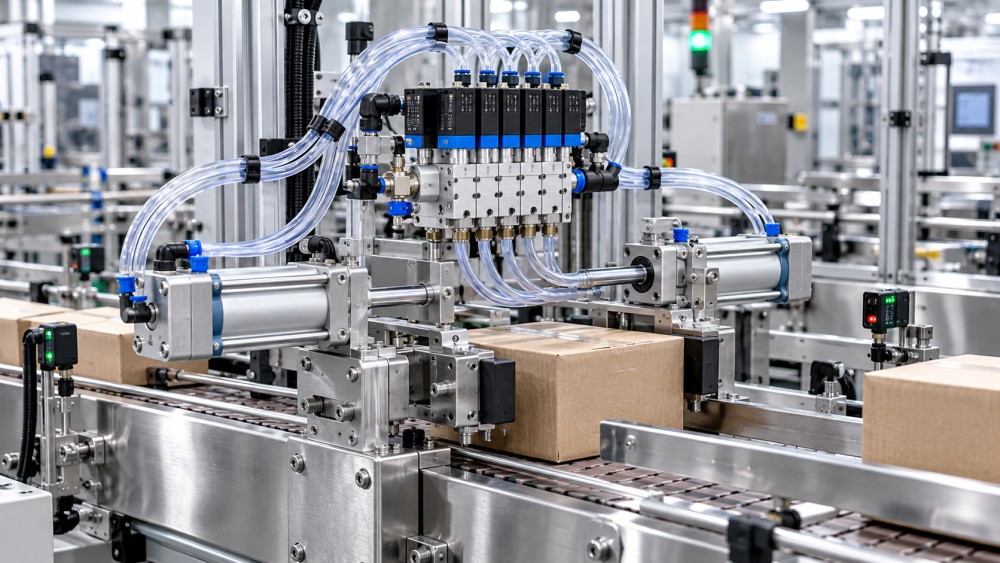
Flow capacity often decides whether speed reaches the cylinder
Valve switching speed and pneumatic flow capacity solve different problems. The first determines how rapidly the flow path becomes available; the second determines how rapidly enough air mass can enter or leave the cylinder chamber. A compact direct-acting valve can switch quickly but still be too small to accelerate a large-bore cylinder or evacuate a high-volume circuit within the required time.
Size flow from the cylinder volume, desired stroke time, operating pressure, and allowed pressure drop. Then include the added volume of hoses, fittings, valve cavities, and any connected equipment. Exhaust deserves equal treatment. In a double-acting cylinder, restricted exhaust creates back pressure that reduces net force, delays acceleration, and can make the end position inconsistent. A small silencer, a clogged muffler, or a restrictive flow-control valve can erase the benefit of a high-speed directional valve.
Flow-control devices should normally be reviewed as part of the timing design, not as afterthoughts. Meter-out control can stabilize overrunning loads and prevent abrupt motion, but it restricts the exhaust side. Meter-in control may suit certain resistive loads but can allow unstable movement where the load tends to run ahead of the air supply. The correct arrangement depends on load direction, friction variation, cushioning, and the level of speed control required. Opening every restriction to maximize speed is not a reliable fix; it can create impact, bounce, and longer sensor-settling time.
Distance, manifold layout, and exhaust routing matter
Locating a directional valve close to the actuator reduces dead volume and the delay caused by charging or venting long tubes. This is especially important for short-stroke, high-frequency motion, where hose volume can be large relative to cylinder volume. A centrally mounted valve island may simplify wiring and maintenance, yet it may impose a timing penalty on remote actuators.
The better arrangement depends on the motion. For a large cylinder with a long travel time, central manifolding may have little effect. For a small gripper, stopper, diverter, or pick-and-place axis that must begin moving immediately after a command, remote mounting or locally placed high-flow valve modules can be justified. The same review applies to exhaust: shared manifold exhaust passages can create interaction when several valves vent at once. A circuit that is repeatable in isolated testing can slow down when neighboring axes operate in the production sequence.
Watch for hidden restrictions
Port thread size alone does not establish effective flow. Check fitting bores, hose internal diameter, quick-exhaust devices, check valves, pressure regulators, filter elements, flow controls, and silencers. A sharp bend or undersized push-in fitting near the cylinder can be more consequential than a modest difference in the valve’s published flow rating. On the supply side, inspect whether the air preparation assembly and distribution line can maintain pressure during the highest coincident demand.
Match valve architecture to the duty
Direct-acting valves can provide quick switching for low-flow duties because they do not depend on a separate pilot stage to move the main element. Their practical flow capacity may be limited. Pilot-operated spool or poppet valves often provide higher flow for actuator control, but their response depends on pilot dynamics and pressure conditions. Neither style is universally “faster” at the machine level; the correct choice follows from required flow, allowable delay, pressure range, and control function.
Spool valves are widely used for directional control, but internal leakage characteristics and crossover behavior should be considered where pressure retention, intermediate positions, or precise sequencing matters. Poppet designs can offer different sealing and switching characteristics. For high-frequency cycling, assess the rated duty, coil heating, contamination sensitivity, and serviceability alongside response time. A coil that becomes hot during sustained operation may change electrical behavior, while contaminated pilot passages may introduce variable delay long before total failure occurs.
Valve configuration also affects the sequence. A 3/2 valve controlling a single-acting actuator, a 5/2 valve driving a double-acting cylinder, and a 5/3 valve selected for a specific center condition will not behave the same after the output signal is removed. Center-exhaust, center-closed, and center-pressure arrangements have different consequences for recovery, holding, venting, and restart behavior. Select the function from the process state required during normal operation and interruption, then assess response performance.
A practical validation sequence
When a machine misses its required cycle rate, verify the source of delay in order. Begin with a time trace that includes the command signal and actual position feedback. If available, add pressure measurement near the cylinder ports. This separates output delay from pneumatic filling and separates pneumatic delay from mechanical sticking or cushioning.
- Measure the interval from controller command to valve coil energization. Check output module behavior, interlocks, fieldbus update timing, and cable voltage drop.
- Measure or observe the interval from coil energization to outlet-pressure change. A repeatable delay here points toward the valve, pilot supply, or electrical drive.
- Compare pressure rise or decay at the valve outlet and near the actuator. A widening difference indicates downstream volume or restriction.
- Check breakaway behavior under the actual load. Rod misalignment, seal friction, side loading, and guide binding can delay movement despite adequate pressure.
- Review the final portion of travel. Cushioning set too aggressively, mechanical stops, impact, and sensor placement can consume more cycle time than initial valve switching.
- Repeat the test with the realistic number of simultaneous axes. Observe supply pressure and shared exhaust behavior instead of testing one actuator in isolation.
This approach prevents unnecessary replacement of a valve that is functioning within its design limits. It also identifies when a faster valve is the correct response: the electrical command is timely, pressure at the valve changes too slowly, and the available timing margin is genuinely constrained by switching rather than downstream flow or mechanics.
Specify response performance as a system requirement
For a procurement or design specification, describe more than “fast response.” State the actuator type and bore, stroke, load behavior, working-pressure range, required cycle sequence, maximum permitted command-to-motion delay, required repeatability, and expected simultaneous demand. Include the intended mounting distance, tubing size, allowable exhaust treatment, electrical supply range, and whether response must be verified in both directions.
Require that quoted valve response data identify its test basis, and distinguish it from the required cylinder-motion time. For critical stations, define acceptance around the machine-level event that matters: pressure reaching a functional threshold, motion beginning, arrival at a sensed position, or completion of a safe venting action. That wording gives designers and suppliers a usable target and prevents a catalog value from being mistaken for a guaranteed automation outcome.
Fast response pneumatic valves deliver value when their switching characteristics, flow path, and installation are coordinated with the automation cycle. The most dependable design is not necessarily the valve with the smallest stated response time; it is the circuit that preserves enough timing margin after real pressure, flow, load, and control conditions are accounted for.
Related News
- How to Assess a Rigid Coupling Supplier for Bore Accuracy and Traceable QualityOct 08, 2026Tribology & Kinematics Expert
- Titanium Alloys Compared: Balancing Strength, Corrosion Resistance, and MachinabilityOct 08, 2026CNC Kinematics Architect
- Where Ductile Iron Dismantling Joints Reduce Alignment Risk in Water PipelinesOct 08, 2026Pipeline Metallurgy Scientist
- Selecting a Precision Bearing Sleeve: Fits, Runout, and Material ChoicesOct 08, 2026Tribology & Kinematics Expert
- Face Milling Cutters: How Insert Geometry Affects Finish on Steel and AluminumOct 08, 2026CNC Kinematics Architect
- Single-Acting Cylinders for Clamping: Stroke, Force, and Return Spring ConsiderationsOct 07, 2026Fluid Power Control Strategist