
How to Select Flat Vacuum Suction Cups for Thin Sheets and Uneven Surfaces
Selecting flat vacuum suction cups sounds simple until the parts start bending, slipping, marking, or dropping in the middle of a production cycle. Thin sheets and uneven surfaces are where many handling systems reveal their weaknesses. A cup that works well on rigid, smooth components may perform poorly on laser-cut sheet metal, flexible plastic panels, coated plates, or slightly warped blanks. For technical evaluators, the real task is not choosing a suction cup by diameter alone. It is deciding which cup design will maintain grip, protect the workpiece, and stay stable under actual plant conditions.
The challenge becomes more critical in automated machining, fabrication, packaging, stamping, and material transfer lines, where inconsistent pickup creates downtime that is harder to diagnose than a clear mechanical failure. Vacuum handling often fails quietly: micro-leakage, lip collapse, surface contamination, or part deflection gradually reduce reliability. That is why flat cup selection should be treated as a system decision, not a catalog shortcut.
This guide looks at how to evaluate flat vacuum suction cups for two difficult conditions at once: thin sheets that deform easily and uneven surfaces that resist full sealing. The goal is practical selection logic that supports safer handling and better long-term automation performance.
Why thin sheets and uneven surfaces complicate vacuum gripping
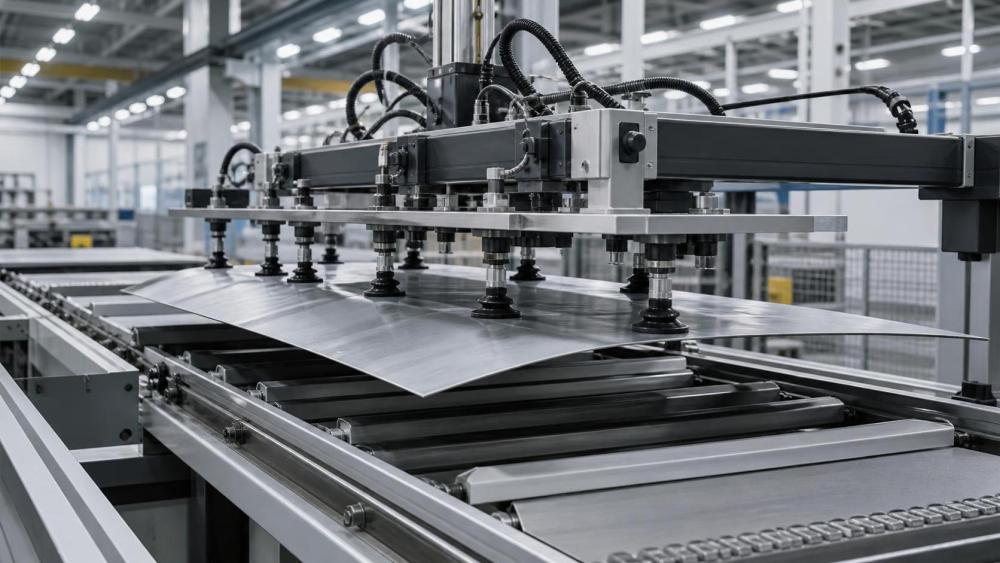
Thin sheets create a unique problem because the workpiece itself becomes part of the gripping equation. When vacuum is applied, the sheet may bow upward, flex at the edges, or lift unevenly before the full seal is established. In severe cases, the suction cup does not lose grip because the vacuum source is too weak; it loses grip because the part shape changes under load.
Uneven surfaces introduce a different but related issue. Flat vacuum suction cups rely on stable contact across the sealing area. If the surface has weld scale, shallow corrugation, orange-peel texture, minor stamping distortion, or residual curvature from forming, the cup lip may only contact a partial ring. That partial contact can still generate holding force, but often with poor repeatability. For high-cycle automation, repeatability matters as much as theoretical holding capacity.
When these two conditions appear together, selection becomes more sensitive. A larger cup may spread load better on a thin panel, yet it may also bridge over surface irregularities and leak. A softer cup may conform better to local unevenness, but it may deform too much during fast pick-and-place motion. This is why technical evaluation should begin with the application itself, not with product dimensions.
Start with the surface reality, not the drawing
Part drawings rarely show the full suction environment. They may provide thickness, nominal flatness, and material grade, but not oil film behavior, local burr patterns, coating texture, or storage deformation after stacking. In actual production, these factors often decide whether flat vacuum suction cups perform reliably.
For technical assessment, it helps to observe or record several basic surface conditions:
- whether the sheet surface is dry, oiled, wet, dusty, scaled, painted, or coated;
- whether the pickup point is truly flat or only appears flat on the drawing;
- whether the part has edge waviness, thermal distortion, or residual curvature;
- whether the panel is lifted from a stack, conveyor, machining fixture, or formed nest;
- whether cosmetic marking is acceptable.
This early review often prevents one of the most common mistakes: specifying a suction cup for ideal geometry while the process actually involves unstable contact conditions.
What makes flat vacuum suction cups suitable in these applications
Flat cups are often selected for high positional accuracy, low internal volume, fast evacuation, and stable handling of sheets, plates, and smooth components. In many industrial systems, they are preferred where cycle speed matters and where the gripper needs predictable vertical pickup rather than deep shape compensation.
That said, not every flat cup is equally suited to difficult surfaces. Small differences in lip thickness, sealing edge profile, friction pattern, support cleats, or cup stiffness can change performance significantly. For thin sheets, the best design is often one that creates enough grip without pulling the material into a distorted shape. For uneven surfaces, the best design is one that tolerates limited irregularity while preserving seal integrity.
In practice, evaluation usually comes down to balancing five variables: cup diameter, material, lip geometry, vacuum level, and dynamic load during motion.
Diameter selection: bigger is not always safer
There is a natural tendency to increase cup size when handling fragile or flexible sheets. A larger diameter can distribute load across a wider area and reduce local stress. That logic is sound, but only up to a point.
If the cup becomes too large relative to the true flat contact zone, sealing performance may worsen. On slightly uneven surfaces, a larger cup has more perimeter that must seal correctly. More perimeter means more opportunity for leakage. On very thin sheets, a large cup can also create a “dishing” effect, where the center lifts while the surrounding material bends, reducing practical grip stability during acceleration.
Technical evaluators should compare not just part size, but usable sealing area. Ask a more operational question: how much of the surface at the pickup point remains flat and stable at the moment of contact? That answer is often smaller than expected.
Where sheet deflection is a concern, using multiple smaller flat vacuum suction cups instead of one oversized cup may improve handling balance. This can reduce local bending, improve orientation control, and provide better redundancy if one contact point encounters contamination or surface variation.
Material choice affects conformity, friction, and part protection
Cup material is one of the most underestimated selection factors. Technical teams often focus on holding force calculations but overlook how material behavior influences sealing consistency and sheet response.
Softer materials generally conform better to slight unevenness and may help create a seal on textured or imperfect surfaces. They can also be gentler on coated, polished, or cosmetic parts. However, soft cups may wear faster, deform under side load, and become less stable in high-speed movement.
Harder materials tend to offer better shape retention and longer wear life in demanding cycles, but they usually need better surface quality to seal well. On thin sheets, a very stiff cup may also concentrate force in a way that increases the risk of local marking or unstable initial pickup.
Environmental compatibility matters too. If the application involves cutting fluids, elevated temperature, outdoor exposure, oxidation, or abrasive dust, material selection should reflect chemical and thermal resistance, not just grip performance in lab conditions.
For evaluators in machining and fabricated metal environments, the right question is not “Which material is strongest?” but “Which material maintains a reliable seal and acceptable wear under this exact contamination and cycle profile?”
Lip design matters more than many buyers expect
Flat vacuum suction cups are often grouped together too broadly, as if all flat cups behave similarly. In reality, the lip design can change the whole performance window.
A thin, flexible lip may adapt better to slight waviness or embossed texture. That can be useful on uneven surfaces where a rigid sealing edge would leak. But a very flexible lip can also flutter, roll, or seal inconsistently if the pickup is fast or slightly off-angle.
A more reinforced lip or internal support structure can help when handling thin sheets that might otherwise be pulled into the cup cavity. This support can reduce deformation and improve release behavior. In some applications, anti-slip patterns or friction-enhancing surfaces are also valuable, especially when horizontal movement or rapid acceleration introduces shear force.
If a line handles multiple part finishes or varying sheet thicknesses, lip design often becomes the deciding factor between a cup that works occasionally and one that works across normal production variation.
Vacuum level and flow stability should be evaluated together
It is tempting to solve handling problems by increasing vacuum level, but more vacuum is not always the best answer for thin materials. Higher vacuum can improve holding force, yet it can also pull delicate sheets into a curved shape, increase marking risk, and amplify instability if the seal is only partial.
For uneven surfaces, sufficient flow capacity may be just as important as vacuum level. If the system can compensate for minor leakage quickly, the cup may remain stable even when the surface is not perfectly smooth. A technically sound evaluation therefore considers the vacuum source, line losses, hose length, valve response, and leakage tolerance together.
In multi-cup systems, the arrangement matters as well. If one cup leaks heavily, does it destabilize the others? Is there local flow control or check-valve protection? These questions are essential when handling sheet stacks, perforated blanks, or parts with varying surface condition.
Dynamic handling loads are where many selections fail
A cup that holds a part in a static test may still fail in real motion. Thin sheets amplify this risk because they behave like flexible structures, not rigid blocks. During acceleration, deceleration, or robot wrist rotation, the part may vibrate, twist, or peel away from one edge of the cup seal.
This is why technical evaluators should review the entire motion profile:
- pickup speed and contact angle;
- vertical lift distance before transfer;
- horizontal acceleration and deceleration;
- presence of sudden stops or orientation changes;
- release accuracy at the destination point.
When a surface is slightly uneven, dynamic forces can turn a marginal seal into a recurring failure. A conservative selection for static holding may still be aggressive in high-cycle automation. In many cases, improving cup placement, adding support points, or moderating motion is more effective than simply changing cup size.
Common selection mistakes in flat vacuum suction cups
Several patterns appear repeatedly in procurement and design reviews.
One is selecting purely by nominal diameter and advertised holding force. This ignores real leakage and part flexibility. Another is assuming the flattest visible area is the best pickup location, even though that area may be structurally weak or prone to deflection. A third is specifying one cup type for an entire family of parts without checking how coating, perforation, residual heat, or edge geometry changes sealing behavior.
There is also a tendency to separate the suction cup from the rest of the handling chain. In reality, cup choice, mounting compliance, vacuum generation, sensing, and robot motion should be reviewed together. A technically sound cup can underperform in a poorly matched system.
A practical evaluation checklist for decision-makers
For technical evaluators comparing options, a useful selection process can be reduced to a short but disciplined checklist:
- Define the real pickup surface, not just the designed surface.
- Confirm how much the thin sheet deflects during initial vacuum contact.
- Match cup diameter to effective sealing area and part stiffness.
- Choose material based on conformity, wear, contamination, and part sensitivity.
- Review lip geometry for minor unevenness and anti-collapse behavior.
- Assess vacuum level together with flow reserve and leakage tolerance.
- Test under actual cycle speed, not bench conditions only.
- Check whether multiple smaller cups improve stability over one larger cup.
- Verify release behavior, especially on smooth coated sheets.
- Monitor performance drift as cups wear or surfaces become dirtier over time.
This kind of structured review aligns with how industrial platforms such as IMPE support equipment evaluation: not by reducing the decision to a single specification, but by connecting material behavior, motion conditions, and process reliability.
When flat cups are appropriate—and when they are not
Flat vacuum suction cups are often an excellent choice for sheet handling when the surface is mostly planar, the cycle requires fast evacuation, and positional accuracy matters. They can also perform well on mildly uneven surfaces if the material and lip are chosen carefully.
But they are not universal. If the surface variation is substantial, if the workpiece has deep contour changes, or if the contact zone shifts unpredictably, a different cup geometry may provide more robust compensation. Technical evaluators should not force a flat-cup solution into an application that fundamentally needs more flexibility. Good selection sometimes means deciding that the obvious option is not the right one.
Final decision criteria that hold up in real production
In the end, the best selection is rarely the cup with the highest nominal force or the widest catalog compatibility. It is the one that keeps grip stable across the ordinary imperfections of production: slight warpage, oil residue, stack variation, worn tooling, rushed maintenance, and daily cycle repetition.
For thin sheets and uneven surfaces, that usually means evaluating flat vacuum suction cups through three lenses at once: sealing reliability, workpiece behavior, and motion stress. If any one of those is ignored, the handling system may look correct on paper and still perform poorly on the floor.
For engineers, sourcing teams, and automation reviewers, a careful selection process saves more than replacement cost. It reduces dropped-part risk, avoids hidden downtime, and creates a handling setup that remains dependable as operating conditions shift. That is the standard worth aiming for when choosing flat vacuum suction cups in industrial applications.
Related News
- How to Assess a Rigid Coupling Supplier for Bore Accuracy and Traceable QualityOct 08, 2026Tribology & Kinematics Expert
- Titanium Alloys Compared: Balancing Strength, Corrosion Resistance, and MachinabilityOct 08, 2026CNC Kinematics Architect
- Where Ductile Iron Dismantling Joints Reduce Alignment Risk in Water PipelinesOct 08, 2026Pipeline Metallurgy Scientist
- Selecting a Precision Bearing Sleeve: Fits, Runout, and Material ChoicesOct 08, 2026Tribology & Kinematics Expert
- Face Milling Cutters: How Insert Geometry Affects Finish on Steel and AluminumOct 08, 2026CNC Kinematics Architect
- Single-Acting Cylinders for Clamping: Stroke, Force, and Return Spring ConsiderationsOct 07, 2026Fluid Power Control Strategist