
Linear Motion Systems for Gantry Automation in Long-Travel Pick-and-Place
A long-travel pick-and-place gantry can appear straightforward on a layout drawing: a bridge moves across a wide work envelope, a carriage travels along the beam, and an end effector collects or places parts. Problems usually emerge after the machine is expected to run at production speed. The bridge may rack during acceleration, the carriage may overshoot at a station, cable carriers may add uneven drag, or repeatability may drift as loads and ambient conditions change.
The practical answer is to select linear motion systems for gantry automation as an integrated motion structure rather than as separate rails, drives, motors, and controls. For long travel, stiffness, synchronized drive behavior, rail alignment, moving mass, and service access normally matter as much as nominal positioning accuracy. A system that is oversized only in motor power but weak in beam stiffness or synchronization can still lose throughput and create maintenance risk.
Start with the motion duty, not the rail catalog
Before comparing guide rail sizes or drive types, define what the gantry must do over a complete operating cycle. A pick-and-place application may have a long horizontal transfer, short indexing moves at each station, vertical motion for pick and placement, dwell time for gripping or inspection, and occasional recovery moves. These actions impose different demands on the motion system.
A useful specification begins with the real payload. This should include the workpiece, gripper or vacuum tooling, brackets, sensors, pneumatic or electrical connections carried on the moving axis, and any moving portion of a cable carrier. The effective moving mass is often higher than the product weight shown in the process brief. Underestimating it can lead to excessive acceleration demands, rail loading, gearbox stress, and poor settling at the target position.
The same review should identify:
- Required travel for each axis, including overtravel, homing space, and maintenance clearance.
- Maximum and normal cycle rates, rather than only the theoretical fastest cycle.
- Positioning tolerance at the pick and place locations and the allowable settling time.
- Load center of gravity, especially when tools extend below or outside the carriage.
- Direction of process forces, such as insertion, pressing, scanning, or contact sensing.
- Operating environment, including dust, chips, washdown exposure, temperature variation, and vibration from nearby machinery.
- Expected production schedule and the access available for inspection, lubrication, belt adjustment, or drive replacement.
These inputs reveal whether the primary challenge is speed, positional stability, structural deflection, contamination resistance, or operating life. They also prevent an early mistake: selecting a compact actuator that fits the travel length but cannot control a wide gantry beam under dynamic load.
Where long-travel gantries lose accuracy
Long travel magnifies small mechanical inconsistencies. A rail mounting surface that is slightly uneven, a beam that flexes near mid-span, or a drive system that applies force from only one side can create behavior that is not visible during slow manual testing. At higher acceleration, those conditions become skewing, vibration, tracking error, or longer settling time.
Racking is one of the most important risks in wide gantry systems. It occurs when the two sides of a moving bridge do not advance identically. The bridge then rotates slightly around its vertical axis, loading the guide blocks unevenly and creating additional resistance. In mild cases, this reduces repeatability. In more severe cases, it can cause binding, abnormal wear, or drive faults.
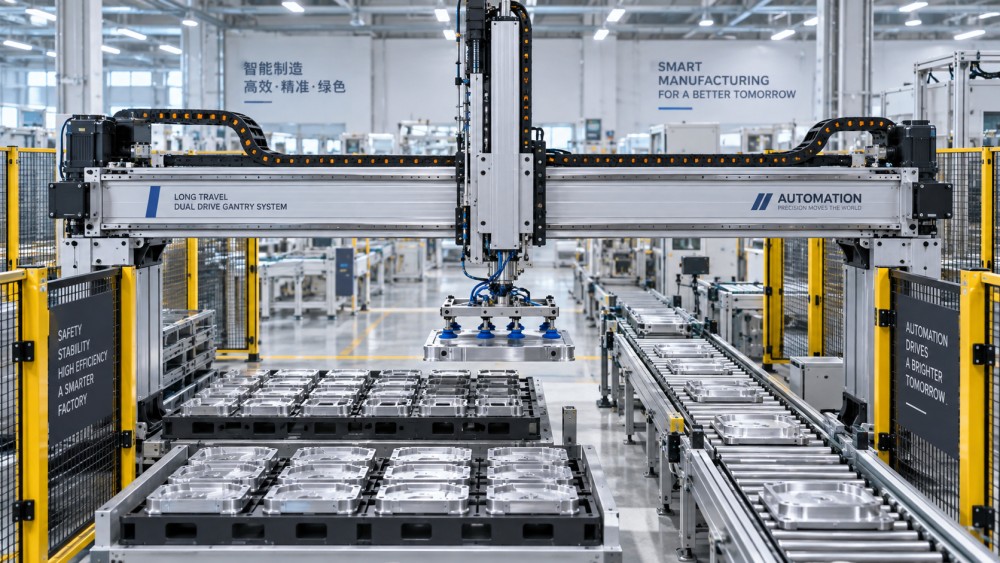
A dual-drive arrangement is commonly used where the moving bridge spans a broad machine width or carries meaningful off-center load. Each side has its own drive source, while the control system maintains electronic synchronization. This approach can provide better force distribution than driving a wide bridge from one side. However, dual drive is not a substitute for mechanical quality. The rails must remain parallel, the beam must be sufficiently rigid, and the drive components on both sides must have compatible backlash, stiffness, and response.
Single-side drive can remain appropriate for narrower bridges, lower payloads, or layouts where a mechanically stiff transmission shaft links both sides. Its limitation is the torsional load placed on the bridge. As span, acceleration, or eccentric payload increases, the structural penalty can become more significant than the apparent savings in drive components.
Match the drive method to travel length and motion behavior
There is no universally best drive for a gantry. The right choice depends on stroke length, speed, load, desired smoothness, allowable backlash, environmental exposure, and the level of maintenance the equipment can realistically receive.
For long-travel pick-and-place, belt and rack-and-pinion drives are often evaluated first because they scale more naturally with length. Belt systems can offer smooth, fast transfer with relatively low moving mass, but they need disciplined tensioning and protection from debris or process contamination. Rack-and-pinion drives handle long paths and higher forces well, particularly on large dual-drive bridges, yet installation quality and lubrication become central to predictable operation.
Ball screws are sometimes selected because they are familiar and can provide high thrust and good positional control. On a long axis, however, screw length introduces critical-speed and deflection concerns. A screw that performs well in a compact station may become unsuitable when extended across a large production cell. The decision should be based on the required velocity, acceleration profile, load direction, and supported screw length—not only on positioning resolution.
Guide rails carry more than the vertical load
Linear guide selection is often reduced to a load-rating calculation, but the guide blocks in a gantry also resist moments. A gripper mounted below the carriage creates a pitching moment. A workpiece picked from one side of a fixture may create roll. An offset payload across the beam introduces yaw forces. During acceleration and braking, these moment loads can exceed the static vertical load contribution.
Rail spacing is therefore a design variable, not just an assembly dimension. Wider spacing between rails on an axis improves resistance to overturning moments, provided the supporting structure is stiff enough to use that spacing effectively. On the bridge axis, spacing between guide blocks also influences how well the carriage resists pitch and yaw. Closely spaced blocks on a long, heavily loaded tool plate may permit movement that appears as inconsistent placement even when encoder feedback is functioning correctly.
Consider preload carefully. A higher-preload guide can improve rigidity and reduce small positional movement, but it increases running resistance and can become sensitive to mounting inaccuracies. A lower-preload arrangement may tolerate assembly variation better but can be less suitable for demanding insertion or inspection tasks. The required balance depends on the process, not on the assumption that tighter preload is always better.
Alignment surfaces deserve early attention
Rails cannot correct a weak or poorly prepared mounting structure. The base frame and beam surfaces should provide suitable flatness, straightness, and rigidity for the selected guide arrangement. Welded frames may require machining or carefully controlled mounting interfaces after fabrication, particularly where long rails are joined. Shimming can be useful for controlled correction, but it should not become a way to compensate for major frame distortion.
During commissioning, measure rail parallelism and straightness according to the system’s precision needs. Check carriage running force across the full stroke, not just near the home position. A carriage that feels smooth over part of the travel can still bind where rail joints, frame transitions, or cable-carrier loads change.
Design the structure around acceleration and settling
High acceleration reduces travel time only when the gantry can settle quickly enough at the destination. A flexible beam may reach the commanded coordinate while the tool is still oscillating. The controller sees position feedback from the encoder, but the end effector can lag because of structural deflection. This distinction matters where parts must enter nests, align with conveyors, engage with pins, or place onto delicate surfaces.
Evaluate beam deflection under static payload and under dynamic acceleration. Static calculations indicate whether the structure remains within acceptable geometric limits. Dynamic behavior requires attention to natural frequency, connection stiffness, and the distribution of mass along the bridge. Large tool plates, hanging cable bundles, and remote-mounted gearboxes can alter the system response.
Several practical adjustments may improve behavior without changing the entire concept:
- Reduce unnecessary moving mass by relocating compatible equipment to the fixed frame.
- Keep the payload center of gravity close to the carriage support plane where process geometry allows.
- Increase beam section stiffness or add structural support when span and payload create excessive flex.
- Use acceleration and jerk profiles that limit excitation of the gantry’s structural modes.
- Review whether the fastest move is actually the process bottleneck; a shorter, stable settling period may improve usable cycle time.
Control tuning should follow mechanical validation, not replace it. Excessive servo gain may mask low-speed compliance while creating vibration, overshoot, or drive alarms at operating speed. A stable machine begins with a sound structure, consistent friction, correct drive sizing, and appropriate feedback placement.
Plan cable management as a moving load
Energy chains, hoses, vacuum lines, sensor cables, and dress packs are frequently treated as secondary components. In a long-stroke gantry, they can affect force demand, repeatability, and service life. A cable carrier that becomes heavy or stiff near one end of travel adds position-dependent resistance. That resistance may be interpreted as a tuning issue when the real cause is routing, unsupported length, bend radius, or unsuitable cable selection.
Route services so that the carrier has controlled support throughout the travel and does not interfere with moving members, sensors, or guarding. Confirm minimum bend radius for hoses and cables, particularly where pneumatic lines feed a vertical axis or rotating gripper. Leave practical access for replacement. A design that requires removal of rails or covers to change a damaged cable may turn a routine repair into extended downtime.
Build commissioning around observable failure modes
Acceptance should not stop at verifying that each axis reaches its programmed endpoints. The useful question is whether the gantry repeats the required task across the full operating envelope, with realistic payload and services installed.
Begin at low speed and monitor running force, motor current, tracking error, and audible changes across travel. Then test acceleration, deceleration, reversals, and representative pick-and-place patterns. Compare behavior near the center of the span, at both ends of travel, and at points where cable carriers change support condition. Differences between locations often reveal alignment or structural effects that a short repeated test will miss.
For dual-driven systems, verify homing logic, master-slave synchronization, fault handling, and recovery after an emergency stop or power interruption. The control architecture should prevent one side from moving independently in a way that twists the bridge. Limit switches, mechanical stops, encoder feedback, and software travel limits should work together, with the protective functions arranged according to the machine’s risk assessment.
Also define what acceptable drift looks like in operation. Gradual changes in positioning, higher current draw, abnormal noise, belt dust, lubrication loss, or uneven rail wear are maintenance signals. Recording these baseline conditions during commissioning makes later troubleshooting more objective.
Procurement questions that reduce integration risk
When comparing components or assembled gantry packages, ask for information that relates directly to the application rather than relying on generic travel and payload claims. Confirm the guide configuration, rail and block arrangement, drive type, motor and gearbox sizing basis, feedback method, cable-carrier arrangement, lubrication points, and structural assumptions behind the stated capacity.
It is equally important to establish interface responsibility. A gantry may be mechanically capable, yet still fail to meet the cell requirement because tooling loads, gripper air consumption, safety guarding, control programming, or fixture tolerances were not included in the original design basis. Drawings should clearly define mounting datums, allowable loads and moments, utility routing, access envelopes, and the division of responsibility for alignment during installation.
For a demanding long-travel application, the most dependable selection process is to validate the full motion chain: frame, rails, carriage geometry, drive, feedback, controls, tooling, and moving utilities. That approach helps prevent a common project outcome—a gantry that works during no-load demonstration but becomes unstable once production payload, cycle rate, and real operating conditions are introduced.
Related News
- How to Assess a Rigid Coupling Supplier for Bore Accuracy and Traceable QualityOct 08, 2026Tribology & Kinematics Expert
- Titanium Alloys Compared: Balancing Strength, Corrosion Resistance, and MachinabilityOct 08, 2026CNC Kinematics Architect
- Where Ductile Iron Dismantling Joints Reduce Alignment Risk in Water PipelinesOct 08, 2026Pipeline Metallurgy Scientist
- Selecting a Precision Bearing Sleeve: Fits, Runout, and Material ChoicesOct 08, 2026Tribology & Kinematics Expert
- Face Milling Cutters: How Insert Geometry Affects Finish on Steel and AluminumOct 08, 2026CNC Kinematics Architect
- Single-Acting Cylinders for Clamping: Stroke, Force, and Return Spring ConsiderationsOct 07, 2026Fluid Power Control Strategist